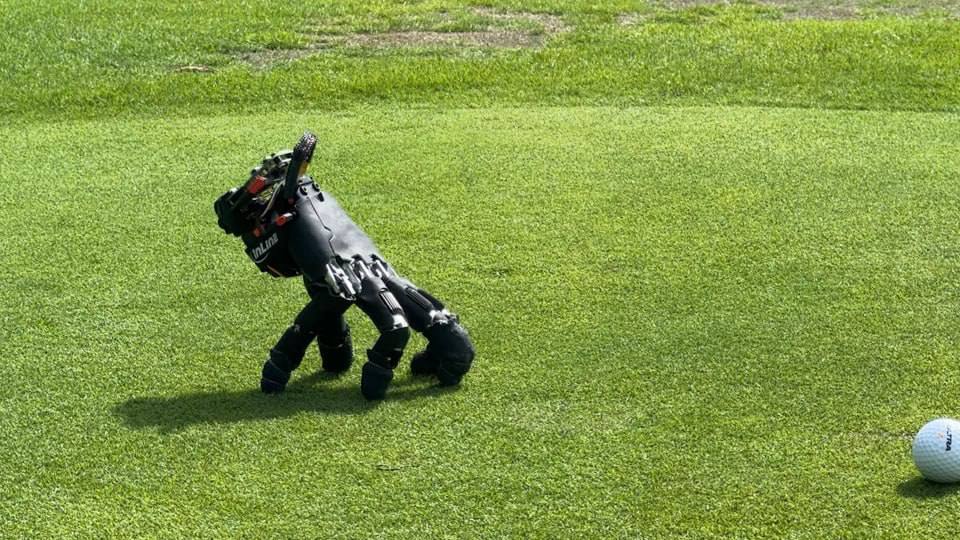
An unusual robotic «butler’s hand» has been unveiled in Switzerland; it can move around independently without wheels or separate legs, using its own fingers as supports. The development was presented by the Soft Robotics Lab team at ETH Zurich. The robotic hand not only crawls across various surfaces, but can also recover after a fall, press keys on a keyboard and move objects.
- A mobile robotic arm based on the commercial WUJI Hand has been developed in Switzerland.
- The development was presented by the Soft Robotics Lab at ETH Zurich.
- The device moves by resting on its own fingers, without wheels or separate legs.
- Roboruka underwent demonstrations on 14 different types of surfaces, both indoors and outdoors.
- She can also press keys on the keyboard and push objects towards a target.
A robotic arm that walks on its own fingers has been developed in Switzerland
A team of researchers from Soft Robotics Lab, ETH Zurich unveiled an unusual robotic arm that uses its own fingers as «legs». The project is called Fingers as Legs, and its authors are Amirhossein Kazemipour, Hehui Zheng and Robert Katzschmann.
This is not simply a joystick attached to the housing, but rather a self-contained mobile system. The robotic hand is equipped with a built-in power supply, sensors and a computing module, enabling it to move autonomously. The total weight of the structure is 818 grams, it has 20 active joints and is capable of both movement and interaction with objects.
How does this robotic arm work?
The main feature of the system is that, whilst moving and carrying out tasks, some fingers can act as supports, whilst others can interact with the surrounding environment. This enables the robotic arm not only to «crawl», but also to perform practical tasks.
According to the ETH Zurich project page, the device has already been demonstrated at 14 types of surfaces — both indoors and outdoors.
and also demonstrated the ability to to recover after a fall. During the tests, it successfully returned to its operating position in 21 out of 25 cases, which corresponds to 84% academic achievement.
It can press keys and effectively control the game
The demonstration of how the robot interacts with the keyboard proved particularly interesting. During the tests, the robot pressed sequential keys without visual confirmation, following the operator’s commands. The project page states that the arm carried out the movements for the game in this way Sokoban.
In the tests, the system performed correctly 29 out of 32 teams, whilst the median delay in pressing the correct button was 0.25 seconds. In other words, the claim that she can «type on a computer» or even «play video games» is backed up by a perfectly genuine demonstration.
Furthermore, with the aid of top-down visual control, the robotic arm was able to push the cube to a specified point. The average error following a series of such attempts was only 17 mm.
Why is this technology needed?
Researchers explain that a mobile robotic arm can be useful in situations where conventional robots find it difficult to operate: in confined spaces, on challenging surfaces, or in environments where both mobility and precise interaction with objects are required.
In the paper itself, the authors note that, in future, such systems may operate in confined spaces that a larger robot or a human cannot access. In effect, this is the concept of a compact «robot butler» capable of moving to the required location on its own, pressing a button, issuing a command or moving an object.
Why it matters
An ETH Zurich project demonstrates a new approach to mobility robotics: when the same system combines locomotion and manipulation. Rather than adding separate wheels, legs or a platform, the engineers taught the robotic arm to use its existing fingers to move and work.
It is not yet a widely used household device, but it represents an important step towards the creation of compact robots that will, in the future, be able to carry out human tasks in complex environments — from laboratories and industry to service applications.